Products
Tsym
Digital open spine surgery simulator
High-fidelity haptic training. Real surgical skills.
Train open spine surgery with real instrument handling, ultra-precise virtual anatomy and objective feedback after every step, without risk to patients.
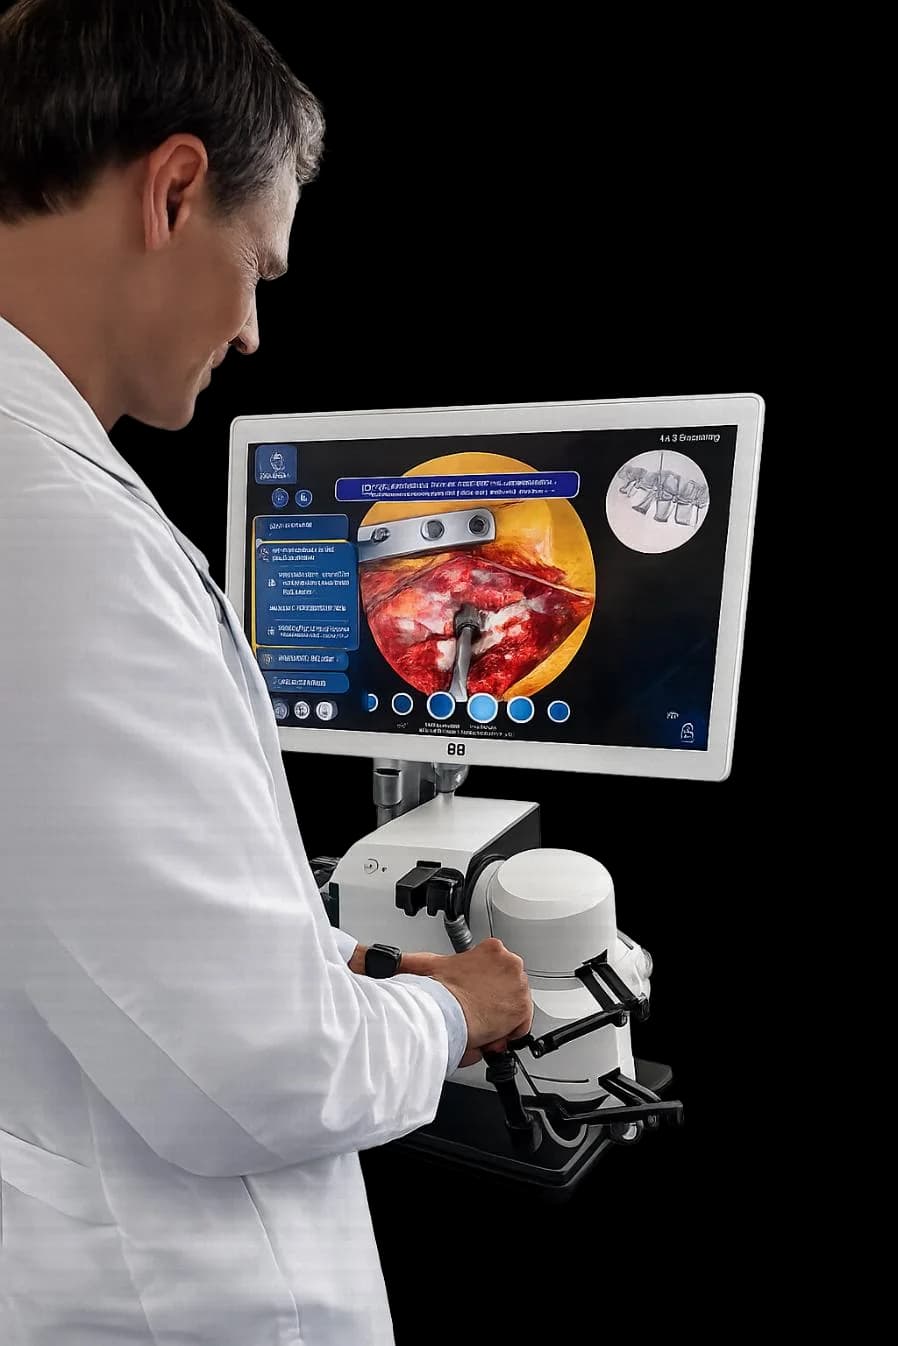
A high-fidelity haptic simulator for complete surgical training
Tsym delivers best-in-class haptic feedback for open spine surgery training. Surgeons build genuine psychomotor skills through ultra-precise virtual anatomy, real instrument handling and real-time performance analytics.
With more than 25 surgical instruments and virtual fluoroscopy to verify tool position in real time, Tsym is a complete, immersive surgical training environment.
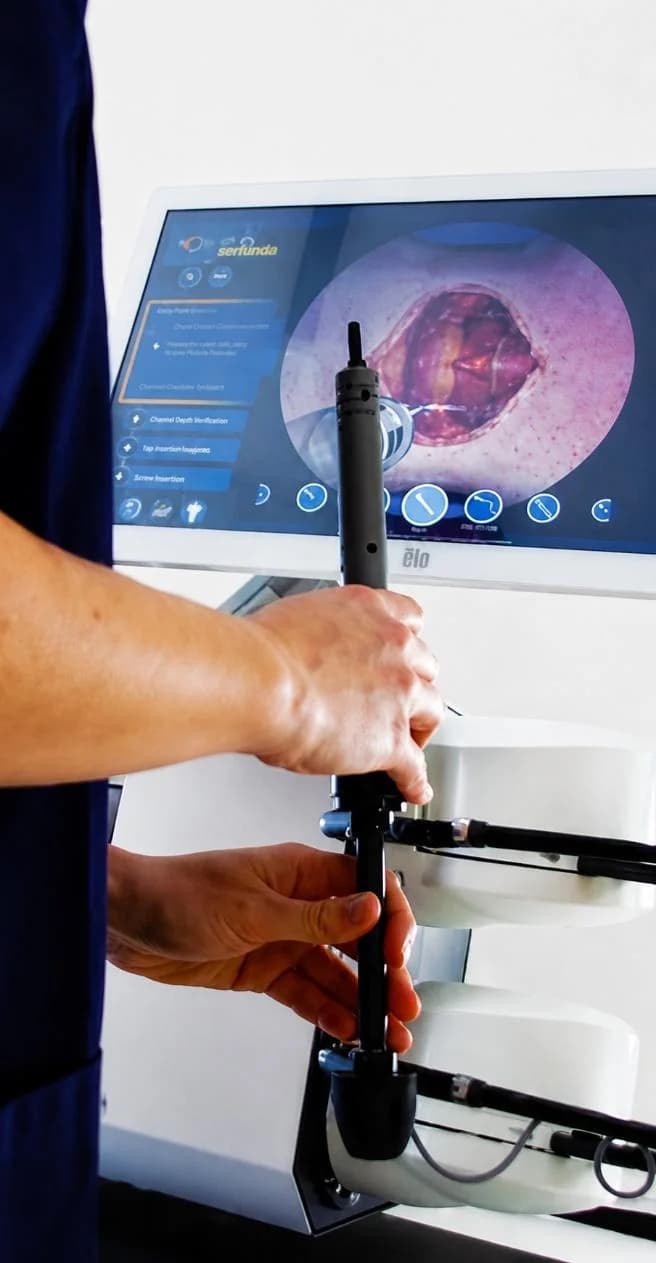
- Best-in-class haptic feedback to reinforce psychomotor skills
- Ultra-precise virtual anatomy with photorealistic rendering
- 25+ instruments, including awl, burr, drill, Kerrison and pedicle finder
- Virtual fluoroscopy for real-time tool and instrument positioning
- Magnification from 1.5× to 10× with full camera control
- Pedal-controlled instruments and fluoroscopy
- AP, LAT and fully customised views in X-ray mode
- Instant feedback and OR tips after each step
Measure and analyse performance in real time
After every session, Tsym gives objective, procedure-adapted metrics, so trainees know exactly which step to go back and practise.
- Width and direction of the pedicle canal
- Quantity of healthy bone resected at each step
- Incorrect or dangerous contact with critical tissues
- Session history and progress tracking
Results and final imaging are saved automatically to each user’s account.
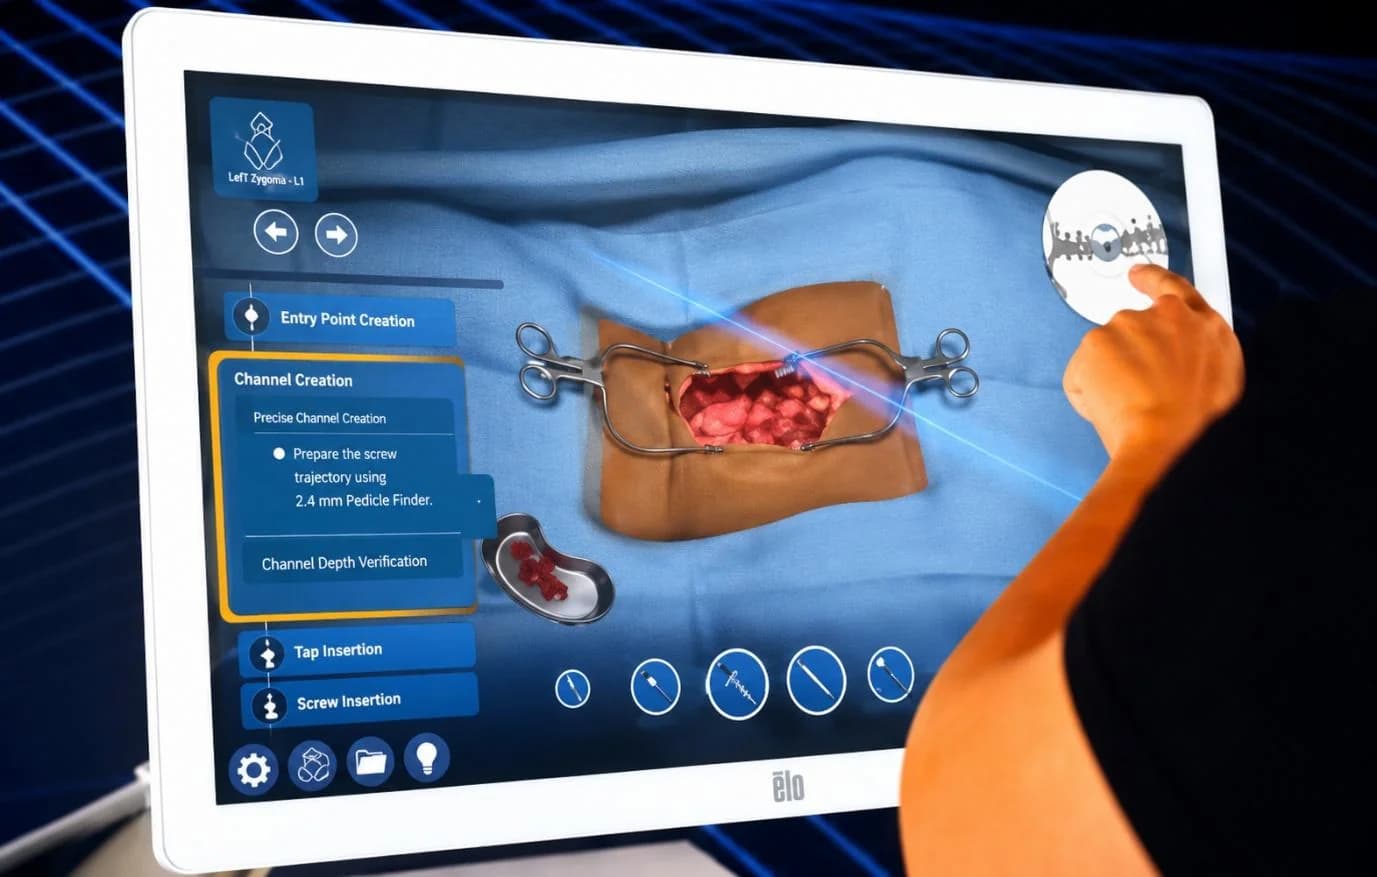
A structured learning pathway, from instruments to patient cases
Three modules take trainees from first contact with the instrument set to complete clinical procedures with patient profiles and imaging.
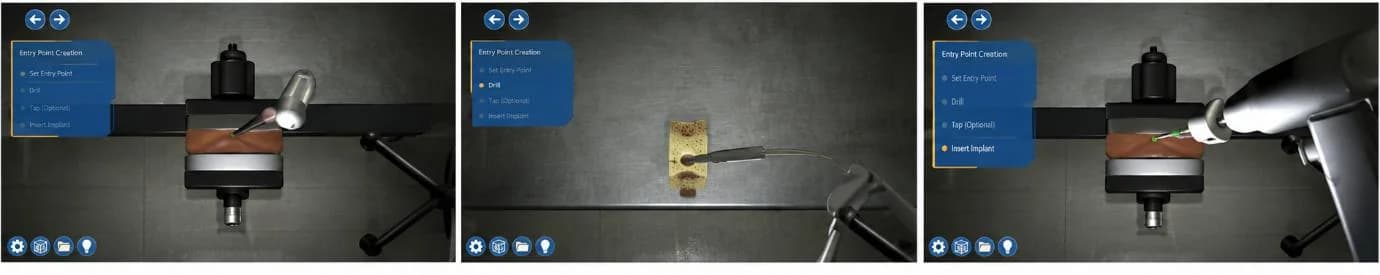
Fundamental skills (dry lab)
Get to know the full instrument set before performing procedures.
Introduction to the awl, burr, depth gauge, drill, Kerrison and pedicle finder. Includes free-form pedicle screw insertion in a scoliotic spine model to build dexterity and instrument confidence.
Surgical techniques
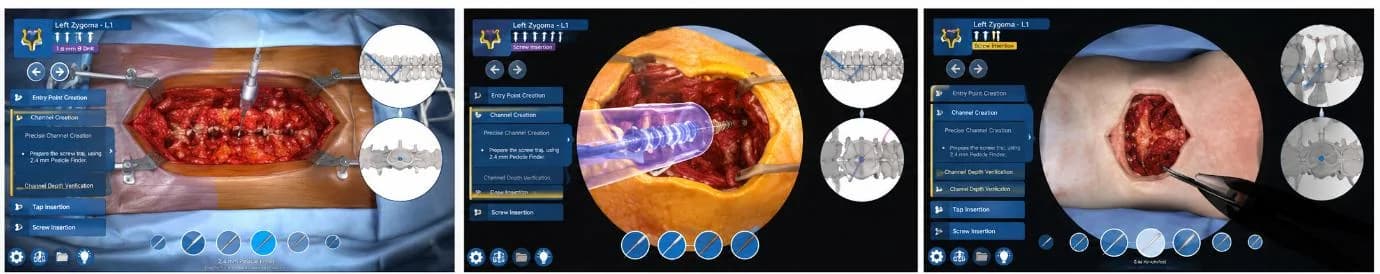
Techniques common to many spine surgeries, and key steps for medtech device implantation.
- Pedicle screw insertion L1–S1
- Transforaminal lumbar interbody fusion L4–L5
- Lateral mass screw insertion C3–C7
- Screw insertion C1–C2
Patient cases
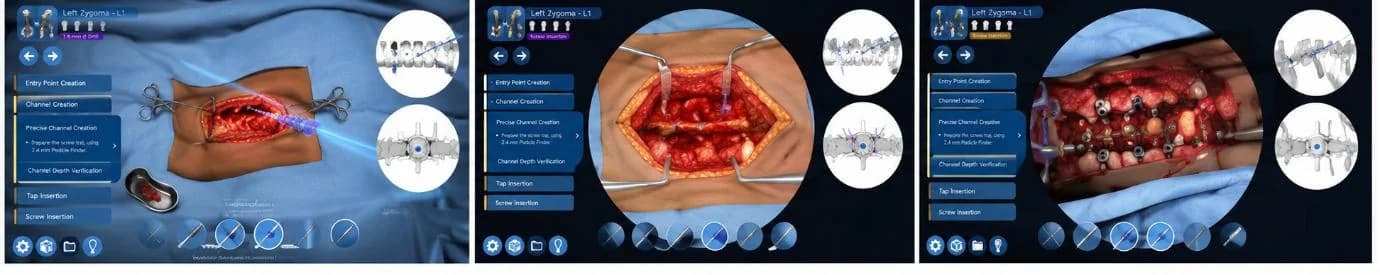
Full spine clinical procedures with complete patient profiles and imaging.
- Right paramedian disc herniation: discectomy L4–L5
- Adjacent segment disease: decompression and fusion C3–C7
- Diffuse bulging disc: laminectomy L2–L3
- Anterior cervical discectomy and fusion C5–C6
- Stenosis: laminectomy C4–C6
Validated by leading surgical institutions
“It makes more sense in terms of being able to follow the sequential steps of the surgery and knowing where you did well or where you need to improve upon… if they want to go back and practice, they can know which step based on the metric.”
“I think that overall the simulation is very good. It allows for excellent re-creation of the surgical skills needed to complete a Discectomy and other spine surgeries.”
Technical specifications
Haptic robot module
- Approx. 45 × 45 × 40 cm
- 5 degrees of freedom haptic feedback
- 3 tool handles for 25+ surgical instruments
- Pedal-controlled instruments and fluoroscopy
Software platform
- New, improved soft tissue simulation engine
- Instant feedback and OR tips after each step
- Results and final imaging saved to user account
- Real-time fluoroscopy: AP, LAT and custom views
Display system
- Single medical-grade 24″ touchscreen
- High-performance dedicated computer
- Magnification 1.5× to 10× with full camera control
Performance analytics
- Width and direction of the pedicle canal
- Quantity of healthy bone resected per step
- Detection of contact with critical tissues
- Session history and progress tracking
Schedule a demo or workshop
Experience Tsym first-hand. Our team can arrange a live demonstration or a training session for your department.